baunuri

I build things end-to-end — from circuit boards to production software.

회로 설계부터 프로덕션 소프트웨어까지, 처음부터 끝까지 직접 만듭니다.


Index of work작업 목록

7 projects · last worked on first7개 프로젝트 · 최근 작업순
A1 Locomotion Reimplementing six legged-locomotion papers on a Unitree A1, from sim to hardware. A blind DreamWaQ policy walks outdoors; the rest are written up in detail, failures included. 최신 4족 보행 논문 6편을 Unitree A1에서 시뮬레이션부터 실제 로봇까지 재구현했습니다. 카메라 없는 DreamWaQ 정책은 실외에서 걷고, 나머지는 실패까지 솔직하게 기록했습니다.
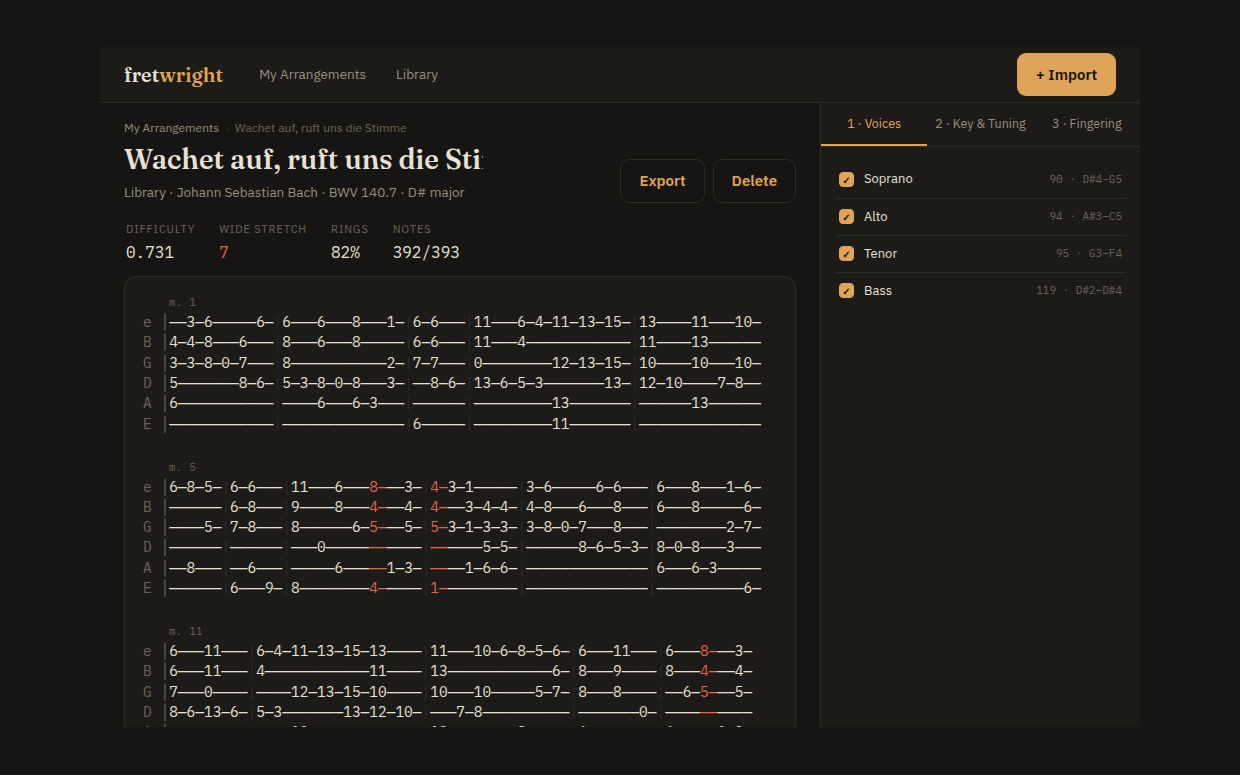
Fretwright Turns MIDI or MusicXML into playable classical-guitar tablature, in the browser. Auto-transposes to the easiest key, with a difficulty knob that thins dense writing down to what your hands can manage. MIDI나 MusicXML을 브라우저에서 바로 연주할 수 있는 클래식 기타 타브로 변환합니다. 가장 치기 쉬운 조성으로 자동 이조하고, 난이도 노브로 빽빽한 악보를 손이 감당할 수준까지 줄여줍니다. Offline for now현재 서비스 중단
ROSDeck Mobile dashboard for ROS 2 robots — teleop, live camera, Nav2 goals, battery, occupancy map. Split panes you can save as presets, like tmux for your robot. No cloud, no account. ROS 2 로봇용 모바일 대시보드 — 원격 조종, 실시간 카메라, Nav2 목표 설정, 배터리, 점유 지도. tmux처럼 분할 화면을 프리셋으로 저장합니다. 클라우드 없음, 계정 없음.

Get it on Google Play →구글 플레이에서 다운로드 →

Learnflow Lesson management for online English academies. Every class is recorded on Teams, transcribed, and analyzed by AI — grammar corrections, engagement scores and CEFR estimates arrive before you sit down. 온라인 영어학원 수업 관리 시스템. 모든 수업이 Teams에서 녹음·전사되고 AI가 분석합니다 — 문법 교정, 참여도 점수, CEFR 평가가 출근 전에 도착합니다. 5,000+ lessons processed5,000건 이상 수업 처리
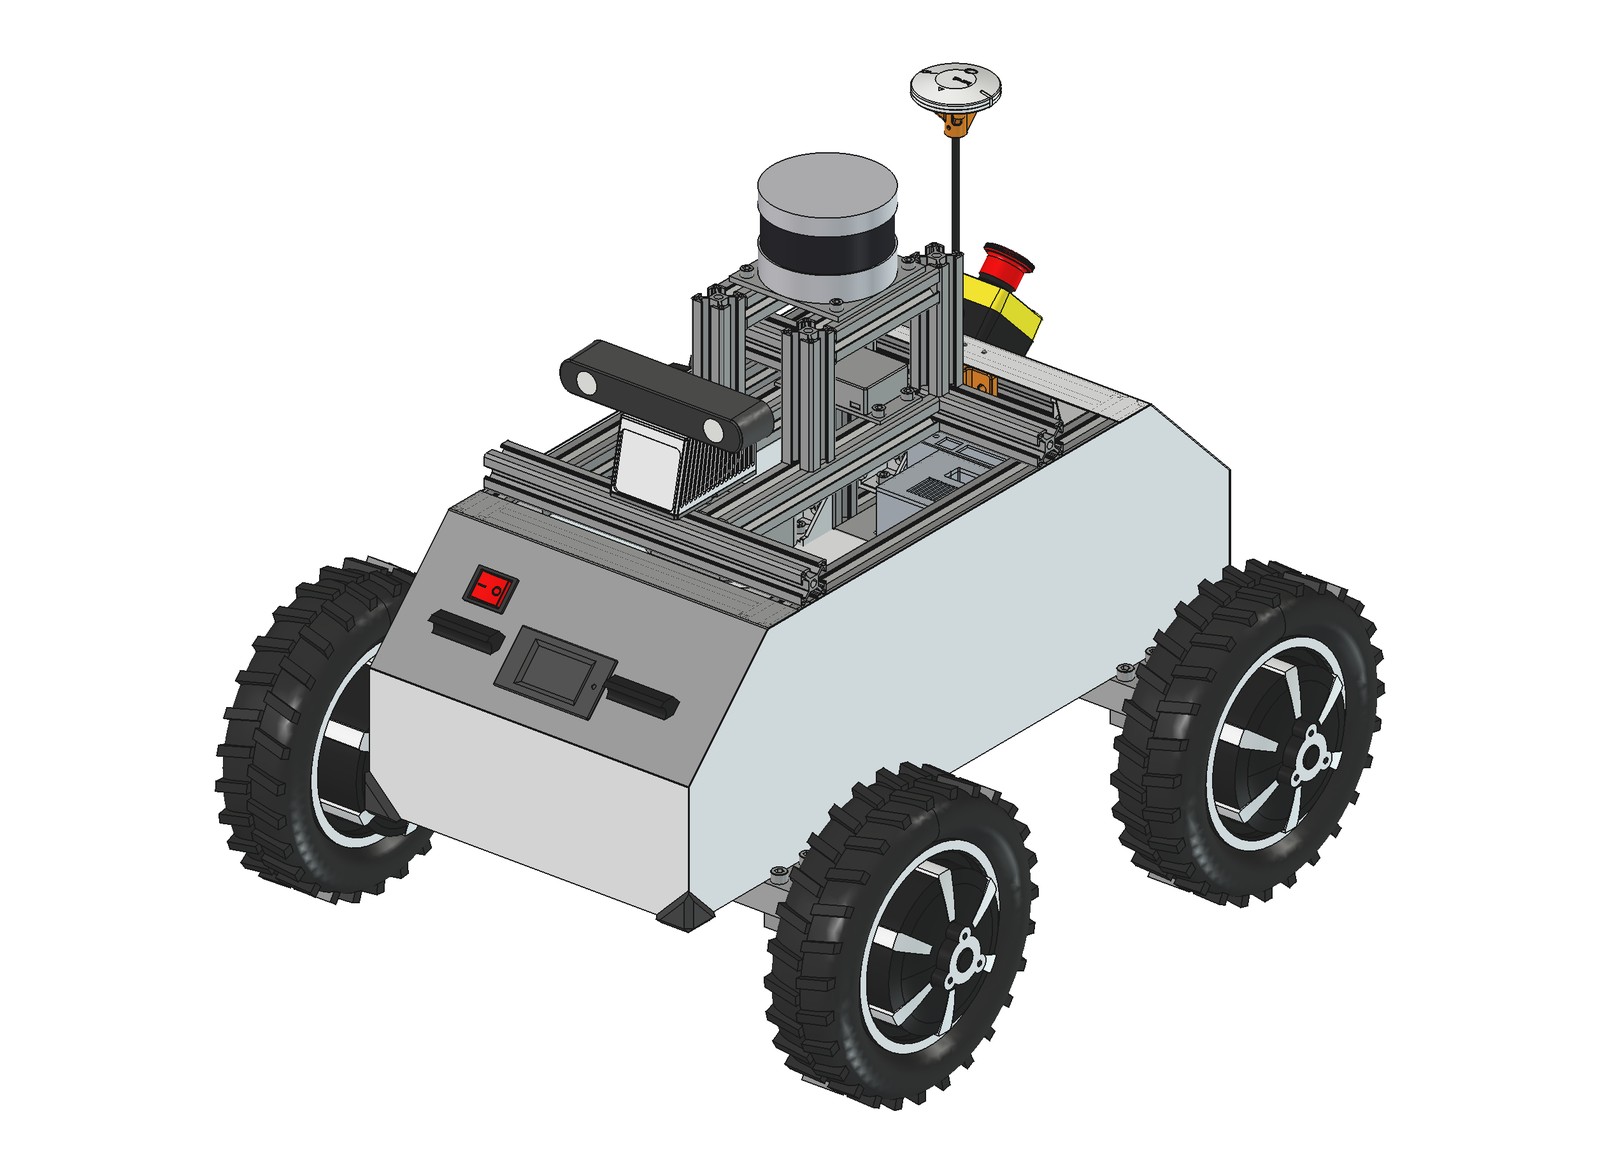
SMUB A four-wheel skid-steer UGV, built from scratch as a research platform for off-road autonomy. Aluminum extrusion, geared hub motors at 70 N·m per wheel, ODrive over CAN, a ROS 2 multi-lidar stack. 험지 자율주행 연구 플랫폼으로 처음부터 직접 만든 4륜 스키드스티어 UGV. 알루미늄 프로파일, 바퀴당 70 N·m 기어 허브 모터, CAN 기반 ODrive 제어, ROS 2 멀티 라이다 스택. ≈ $2,000 in parts against $20,000 commercial부품비 약 $2,000 · 상용 플랫폼은 $20,000
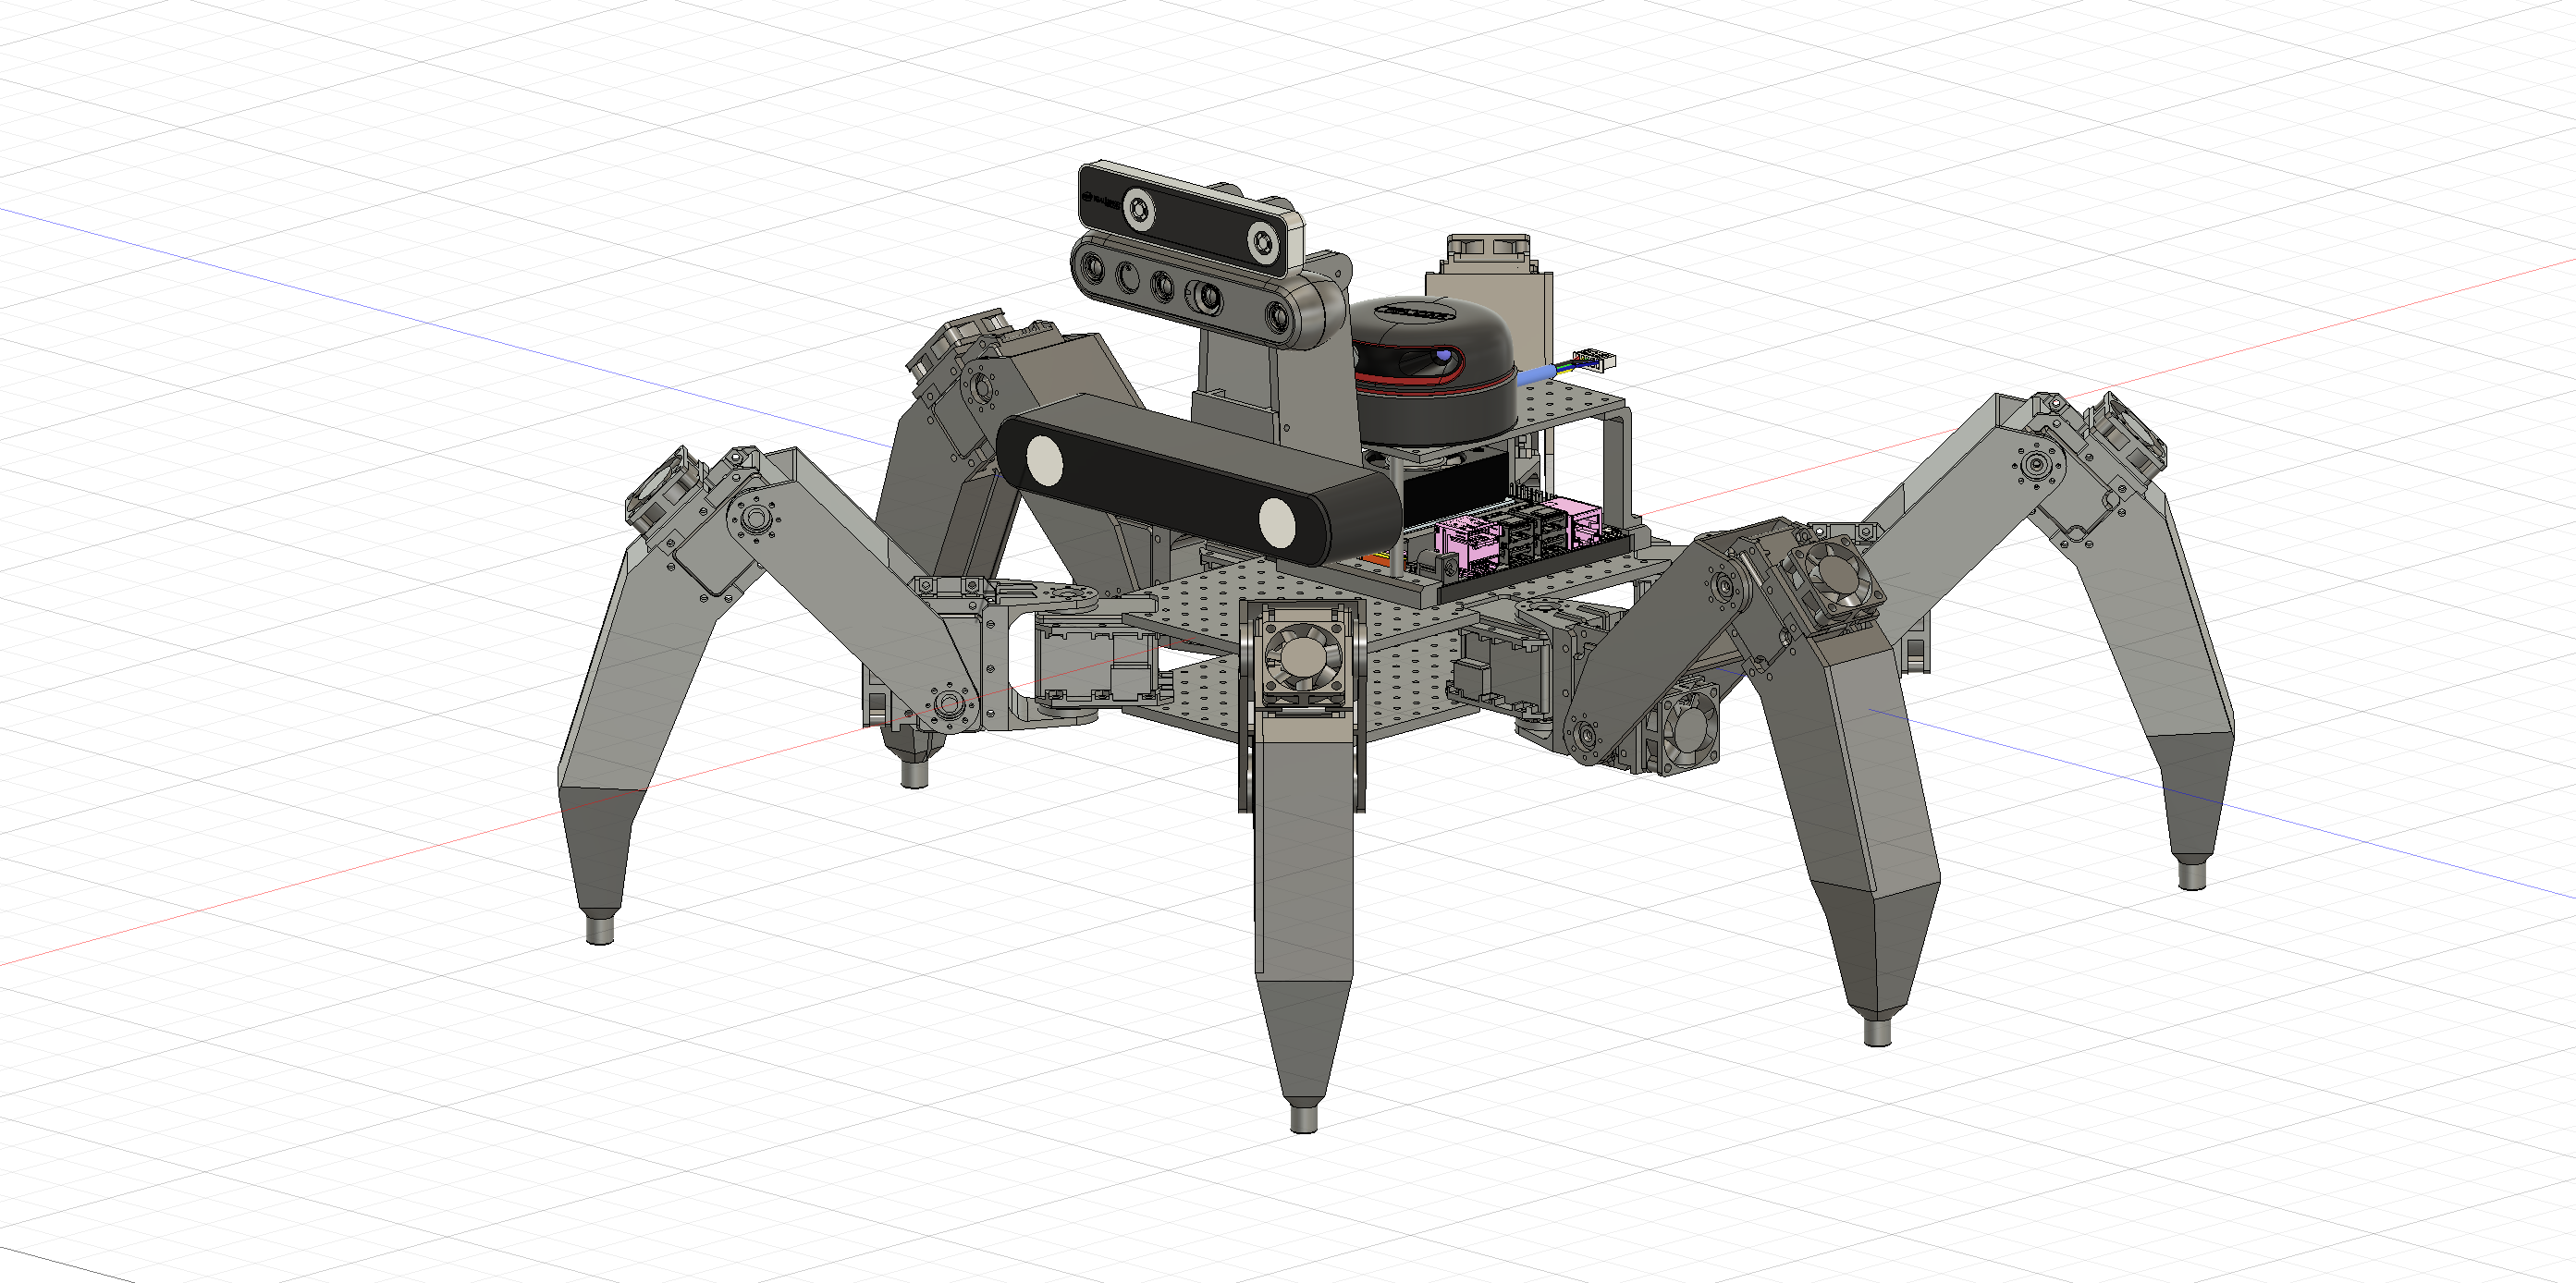
Hexapod A six-legged walking robot, built three times. Each version fixed the failures of the last — from hobby servos that couldn't hold weight to Dynamixel actuators doing SLAM through forest terrain. 세 번에 걸쳐 만든 6족 보행 로봇. 매번 이전 버전의 실패를 고쳐나갔습니다 — 무게를 버티지 못하는 취미용 서보에서 숲 지형을 SLAM 주행하는 Dynamixel 액추에이터까지.
Ownphotos A self-hosted Google Photos alternative, built from scratch with Django and React. Face recognition, image search via faiss, scene detection, map view — without giving up your data. Django와 React로 처음부터 만든 셀프 호스팅 Google Photos 대안. 얼굴 인식, faiss 이미지 검색, 장면 감지, 지도 보기 — 데이터 소유권을 포기하지 않습니다. 2.7k stars · forked into LibrePhotos (8k+) · 1M+ Docker pulls2.7k 스타 · LibrePhotos로 포크 (8k+) · Docker 100만+ 다운로드

About소개

Background in computational neuroscience (Max Planck Institute, Tübingen). Six years as CTO building education platforms used by tens of thousands daily. I build things end-to-end — from circuit design to production infrastructure — and I care about getting the details right.

튀빙겐 막스 플랑크 연구소에서 계산신경과학을 전공했습니다. 6년간 CTO로 일하며 매일 수만 명이 사용하는 교육 플랫폼을 만들었습니다. 회로 설계부터 프로덕션 인프라까지 직접 만들고, 디테일을 끝까지 챙깁니다.


Contact연락처

Have a project in mind? Let's talk.

진행 중인 프로젝트가 있으시면 편하게 연락주세요.